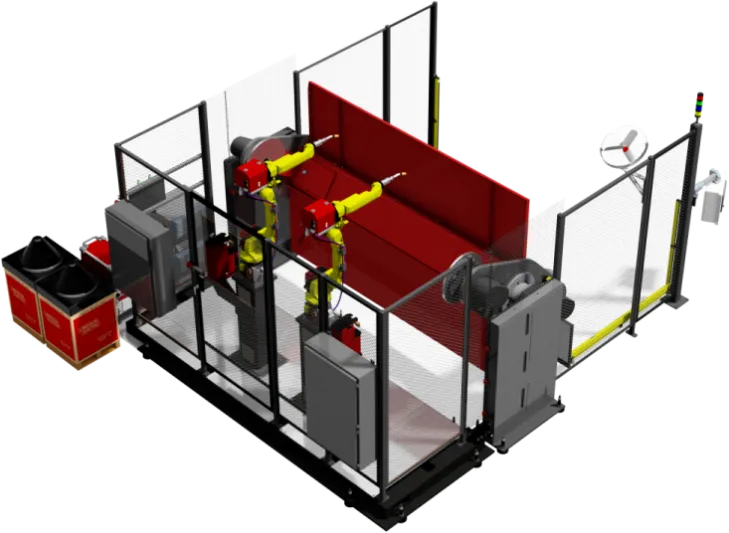
 Design render
Welding
Robotic welding cells
Repeatable seams at production rate, with positioners and guarding laid out around the part and the loading side.
Robotics, Cell Design and Simulation
We design, simulate, build and commission robotic cells for welding, palletising, machine tending, deburring and packing, on the robot platform the process calls for. Cells are delivered turnkey, from the first layout to service and spare parts.
Robot platforms
Collaborative robots
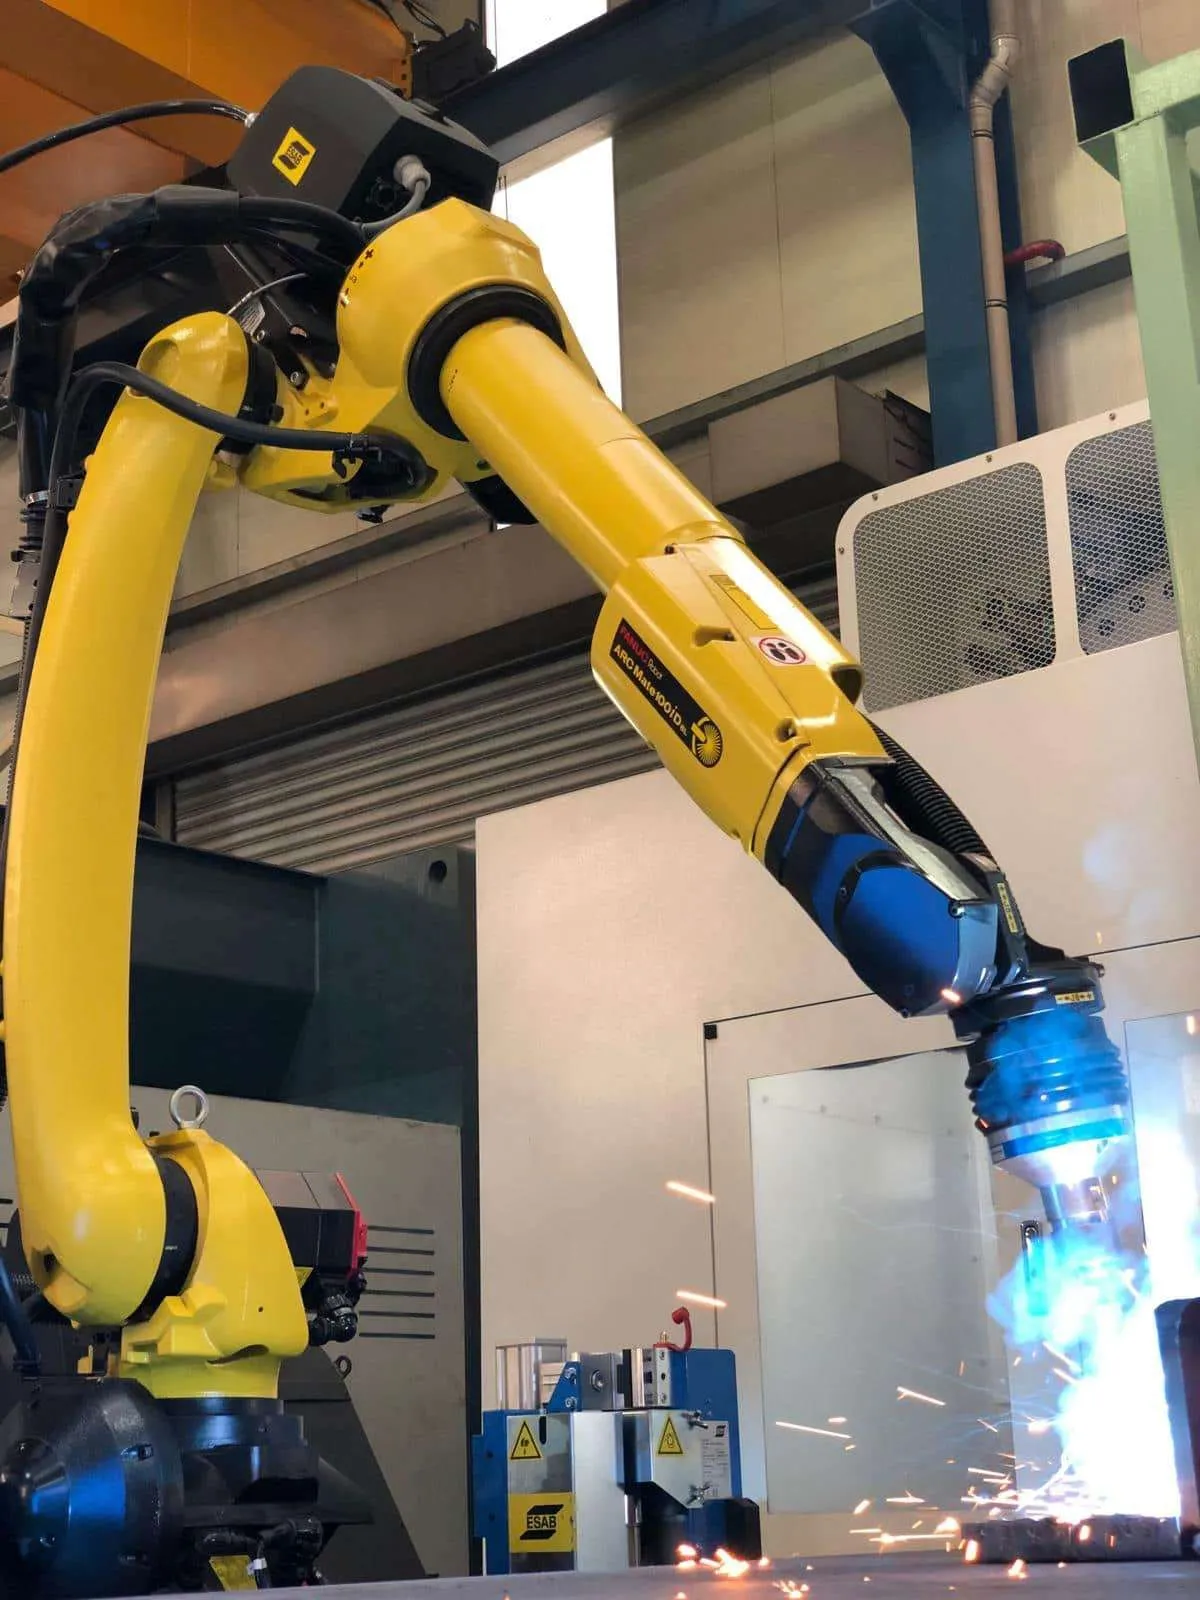 Real image
Cells
Palletising, welding, packing, deburring and machine tending, each laid out around the part, the cycle and the people who work beside it.
The cell, running
Approach
01 / 07
Palletising, layer by layer
Applications
Design renderWelding
Repeatable seams at production rate, with positioners and guarding laid out around the part and the loading side.
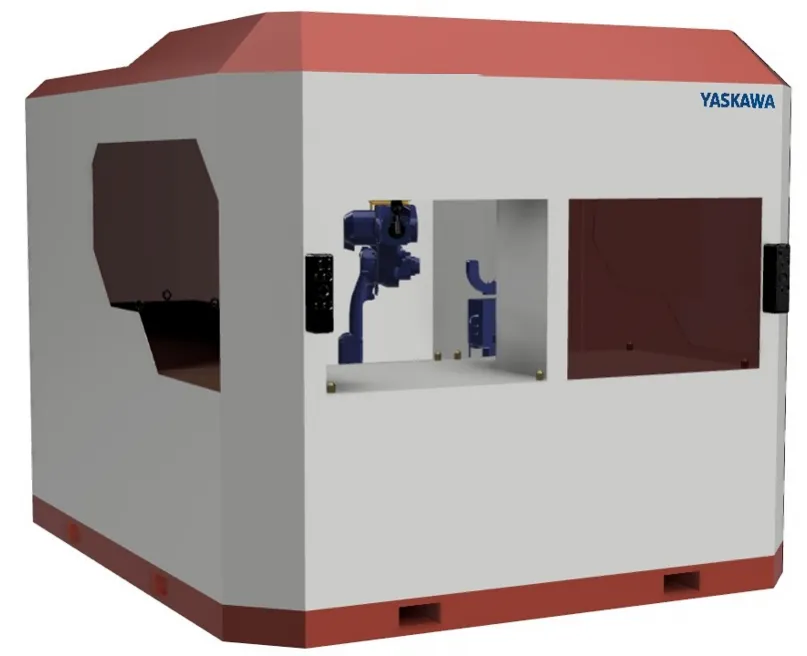 Design render
Welding
A compact, enclosed welding cell that arrives as one unit, ready to set down and connect.
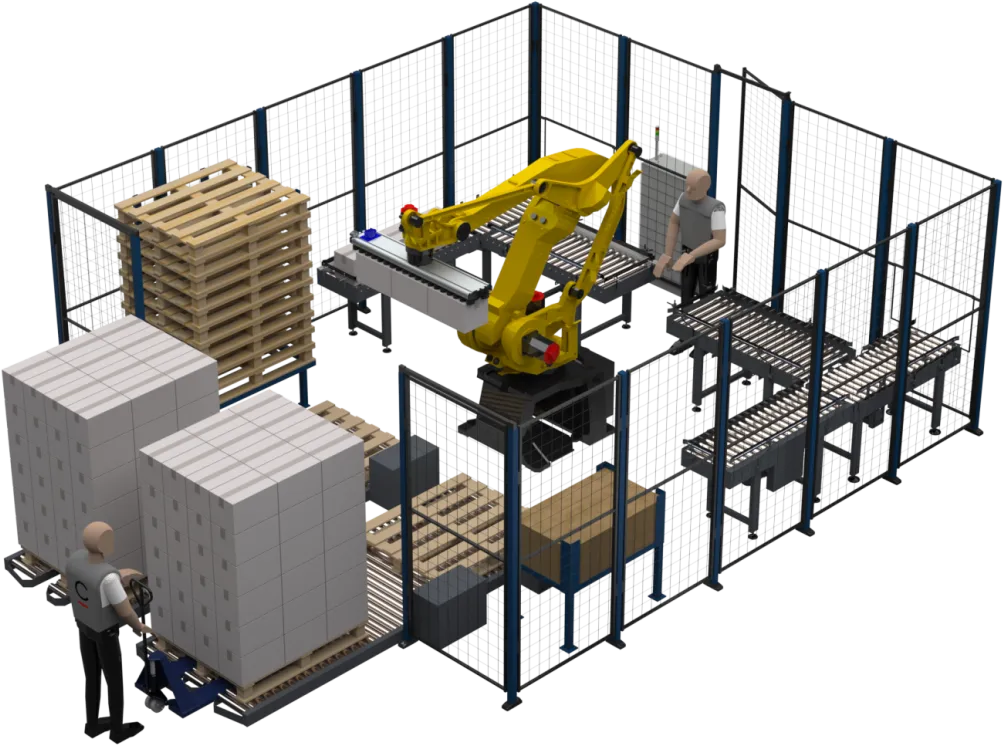 Design render
Handling
Stacking and unstacking bags, sacks and boxes. Comb or vacuum grippers pick one product or several at a time, matched to the line speed.
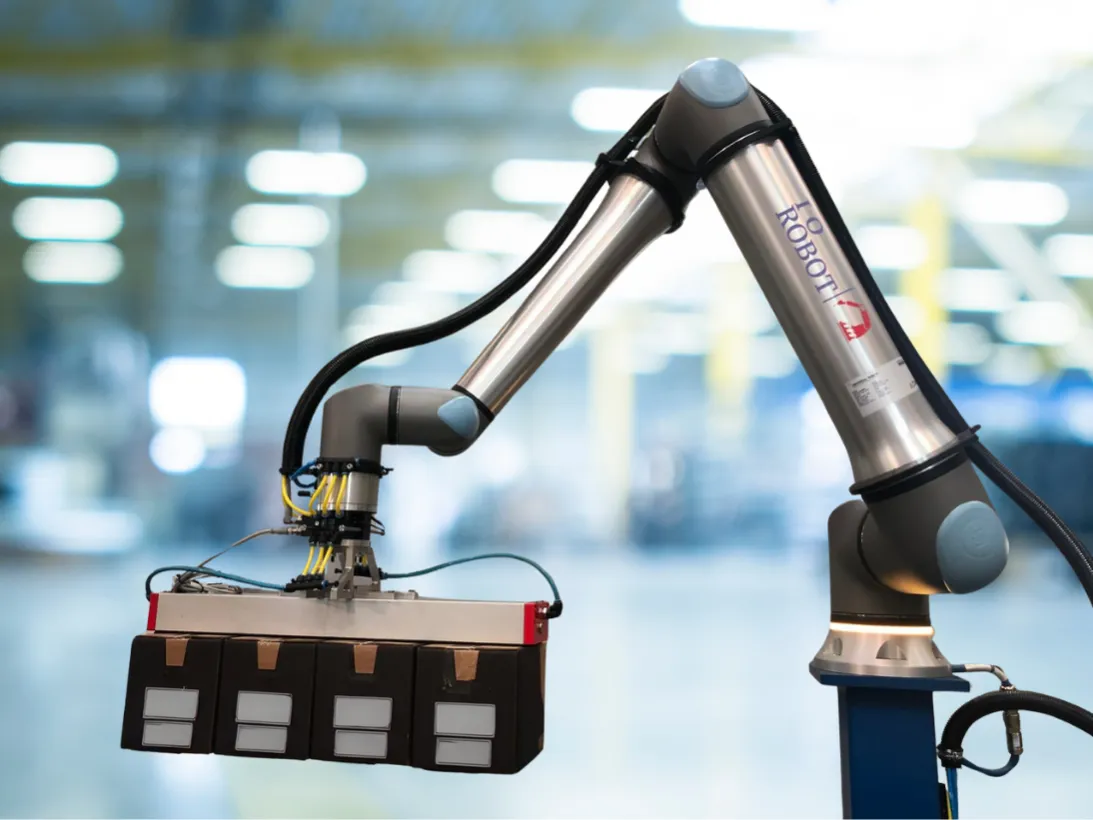 Illustration
Cobot
A UR20 cobot on a robust base, with a vacuum gripper and a centring conveyor with integrated sensors. It handles cases of up to 15 kg and is quick to program.
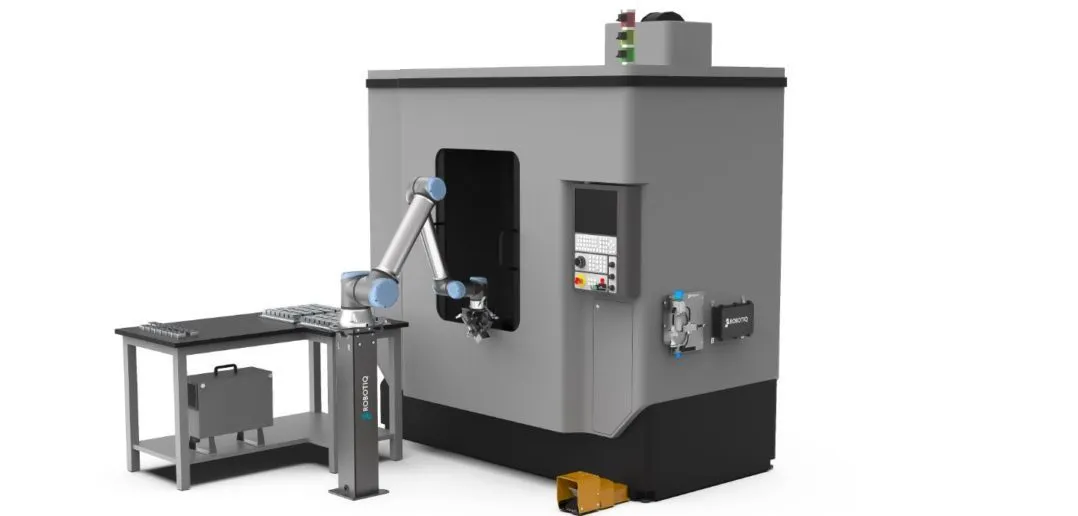 Design render
Tending
Robots and cobots that load and unload machine tools, keeping the spindle cutting through every shift.
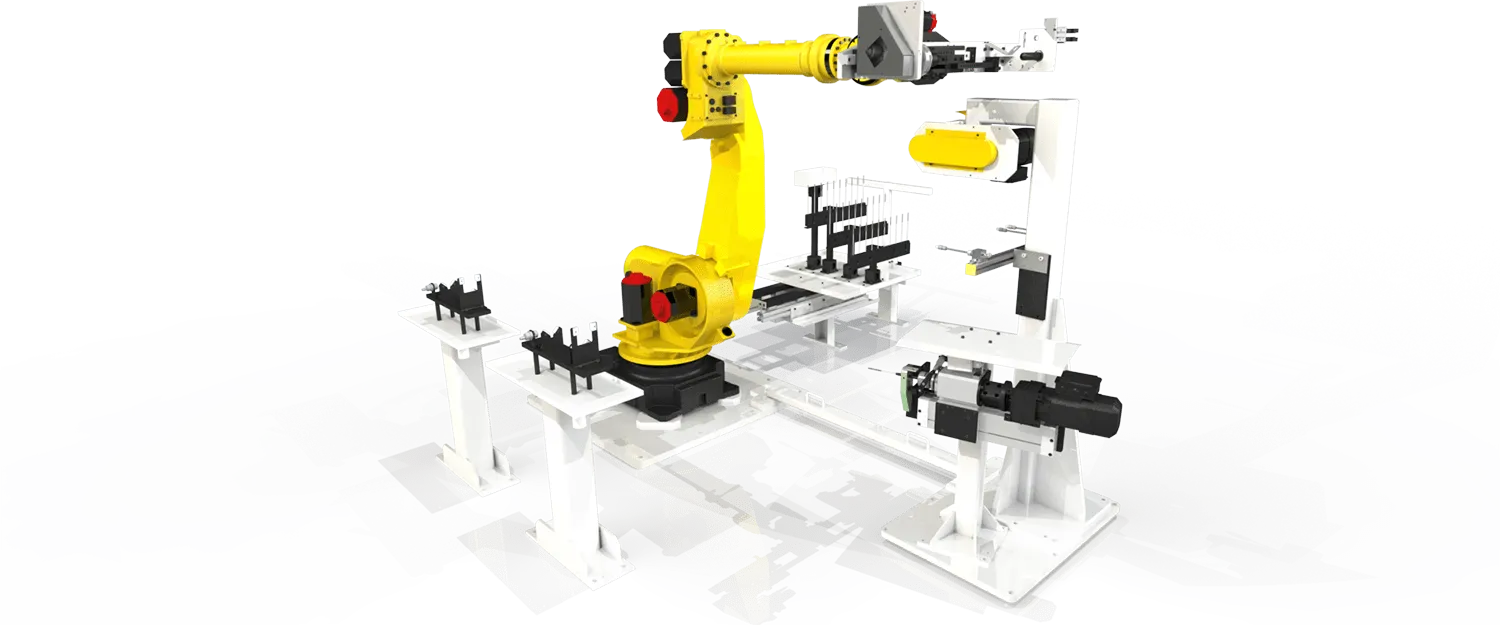 Design render
Finishing
The spindle is carried along the part profile at a set feed, for the same clean edge on every part.
Design and simulation
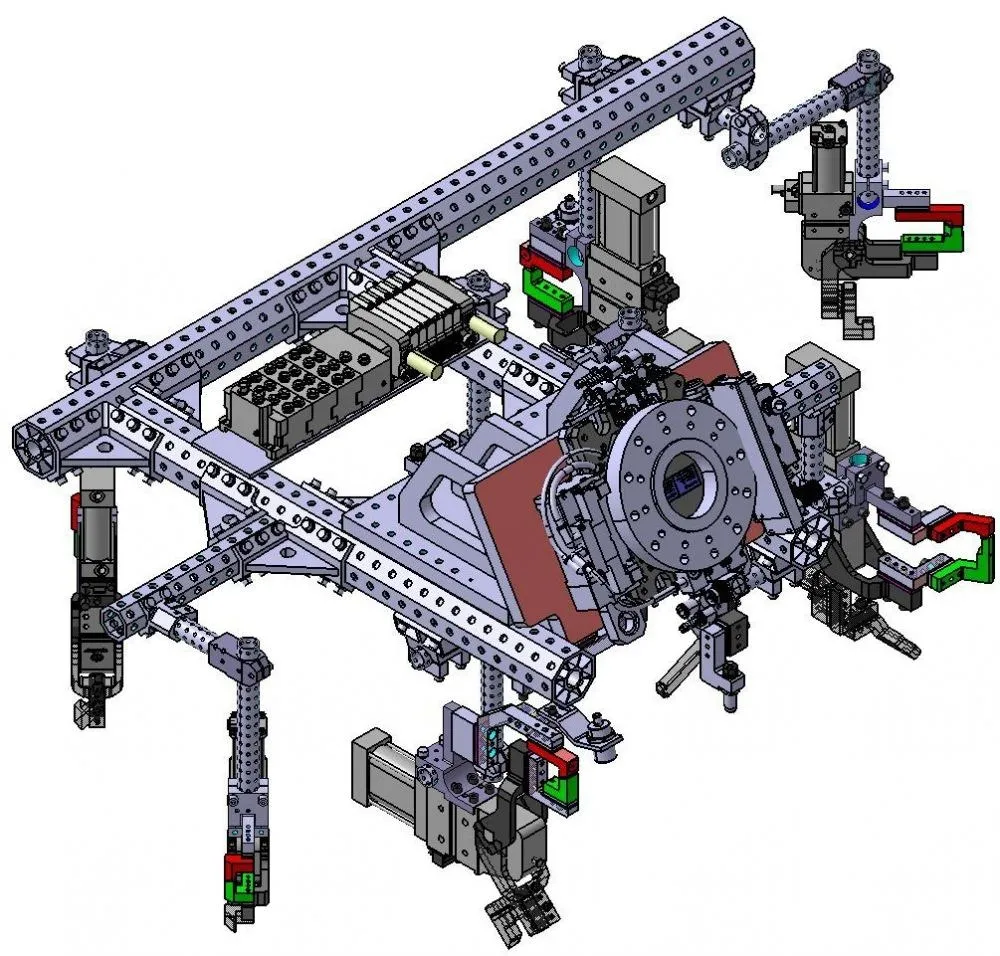
Layout, robot reach, cycle time and clearances are modelled before manufacture, and the end-of-arm tooling is designed around the part. Commissioning then confirms what the model already showed.
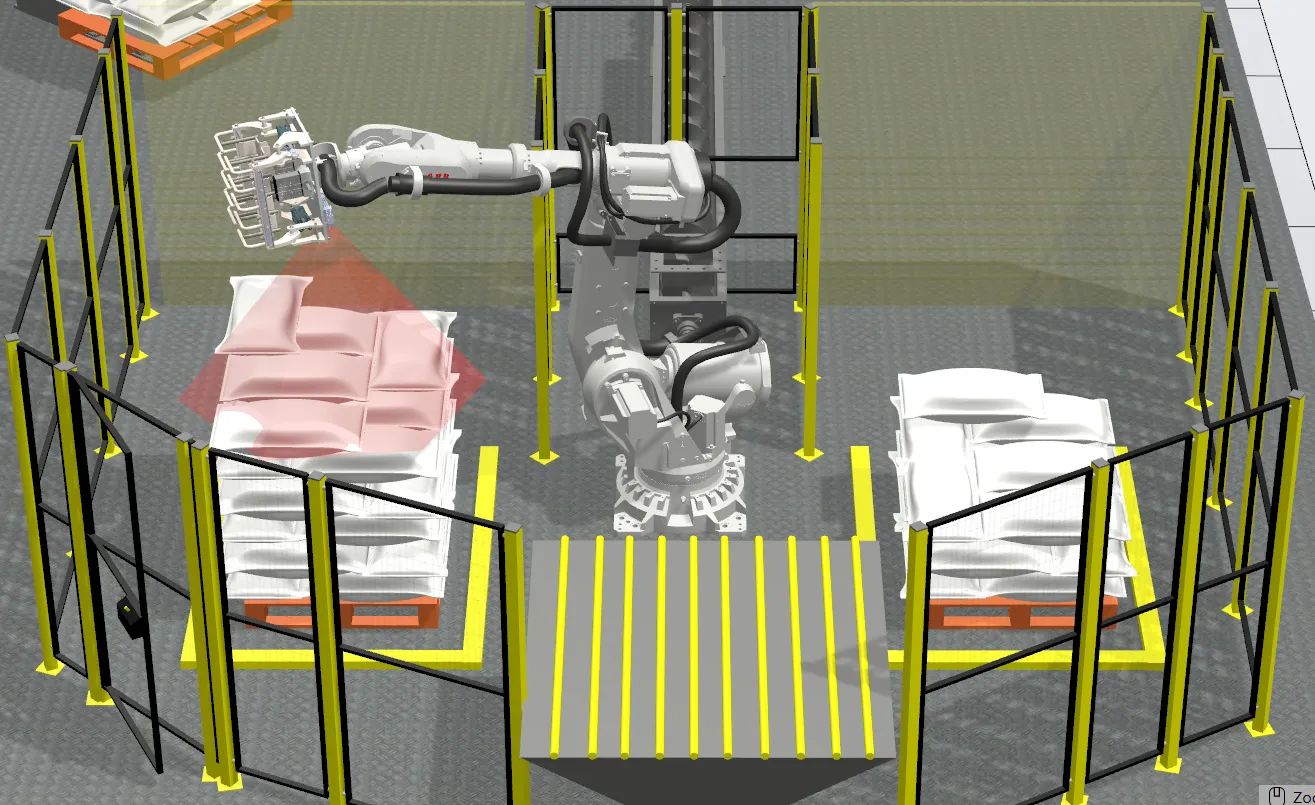 Design render
Why robots
Productivity
Continuous operation around the clock, at a steady rate.
Flexibility
Reprogrammed for new tasks and added to existing lines smoothly.
Quality
High precision and repeatability, for fewer defects.
Safety
Robots take on hazardous, heavy and extreme-environment work.
Cost
Lower labour cost, less waste and rework, and a quick return.
Skilled labour
Production held steady wherever skilled people are scarce.
Reliability
The same task, done the same way, every time.
Data
Process data for optimisation and predictive maintenance.
Automation and special machines
Beyond the robot: the controls, data and purpose-built machines that make a line run as one.
Automation
 Design render
Special machine
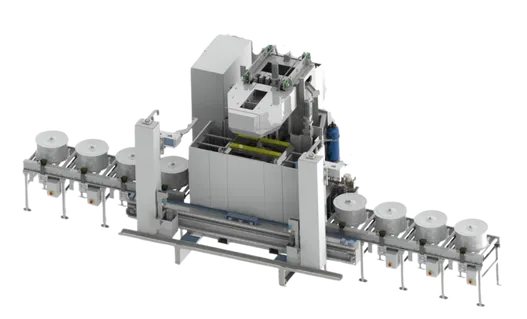
Seals valve holes automatically before the helium leak test, taking over a manual step and raising the reliability of the test. A double 3D camera system detects and measures each valve hole. Average capacity: 423 wheels per hour.
 Design render
Special machine
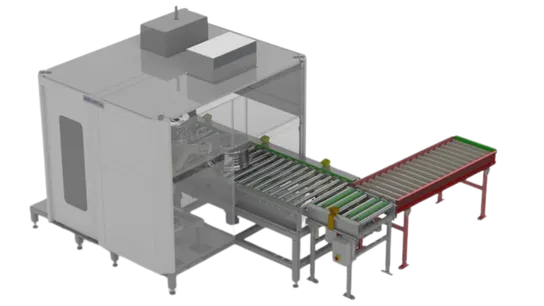
Drills the sprue points of cast aluminium wheels, keeping each wheel true and crack-free. Integrated wheel detection, with an automatic tool changer as an option.
Consultancy and service
Automation is the foundation of digital transformation: efficiency, flexibility, connected production, data analytics and people and machines working together. We combine your process expertise with our automation experience.
Industry 4.0 consultancy
Service and spare parts
Spare parts, maintenance and technical service for ABB, Fanuc, KUKA and Yaskawa robots, so production keeps running.
Robot platforms
Gripping and end-of-arm tooling
At our facilities
Robotic welding cells we built and installed in our production facilities, filmed at work.
Next step
The part, the cycle time and the space the cell has to fit. We will come back with a layout, a simulation and a plan to build it.
Solutions